Haidong (Andrew) Huang

Physical AI / Robotics

Haidong (Andrew) Huang

About Me

Hi, I'm Haidong 👋! You can call me Andrew. I love robots and am dedicated to integrating them safely and reliably into our lives.

I am a junior (third-year) undergraduate at the University of Nottingham, pursuing a Bachelor of Engineering (Honours) degree. Currently, I am a research intern at the SafeAI Lab at Carnegie Mellon University (CMU), under the supervision of Prof. Ding Zhao. Prior to this, I was a visiting student in the Faculty of Computer and Mathematical Sciences at The Hong Kong Polytechnic University (PolyU), advised by Professor Chenguang (Charlie) Yang (Fellow of IEEE/IET/IMechE; Member of EASA and NAAI).

I also spent a wonderful summer at The Hong Kong University of Science and Technology (HKUST)'s Robot Motion Planning and Control Lab, under the supervision of Prof. Jun Ma. I am also an Undergraduate Researcher in the Robot Learning and Control Lab at Eastern Institute of Technology, Ningbo, advised by Prof. Xiaocong Li, and work closely with Dr. Haiyue Zhu from A*STAR.

Research Interests

My research combines robotics, generative models, and control theory to build safe, robust robots that generalize across tasks and environments and can be deployed at scale, enabling precise, contact-rich physical interaction.

  • Atomic Skill Learning and Compositional Generalization

    Learning reusable skills, interaction priors, and local models. Studying skill specialization and representations that separate motion from environmental conditions (CoRDE, ALAS), while determining what to learn from experience and what to leave to planning and inference. Composing skills under changing goals and physical constraints (MetaWorld-X, CompoHOI), with coherent long-horizon transitions (ActAtlas) that prepare subsequent skills across unfamiliar objects, environments, and task sequences.

  • Dexterous Manipulation and Contact-Rich Interaction

    Learning expressive, coordinated hand control through human coordination priors, structured exploration, and visual, tactile, and force feedback. Studying how active interaction resolves uncertainty about changing contact and force constraints (IAC), and how actions reshape contact, force transmission, and future motion feasibility (T-FRAME), to coordinate fingers and forces for stable, precise manipulation that advances tasks while preserving future options.

  • Generative Policies and Closed-Loop Control

    Developing diverse generative policies that preserve task-relevant geometry from perception to action (GeoPreserve). Learning from action consequences to distinguish outcome-preserving variations from errors requiring feedback correction (CQ-FM), integrating dynamics and control constraints, and balancing trajectory objectives while reducing sensitivity to scales and extreme values (RBPN), for reliable, physically feasible, computationally efficient execution under uncertainty.

I am also exploring agentic robotics (ongoing).

More broadly, I am passionate about research that is both scientifically impactful and intellectually stimulating.

News

Publications & Manuscripts

* Equal contribution† Corresponding author‡ Project Leader

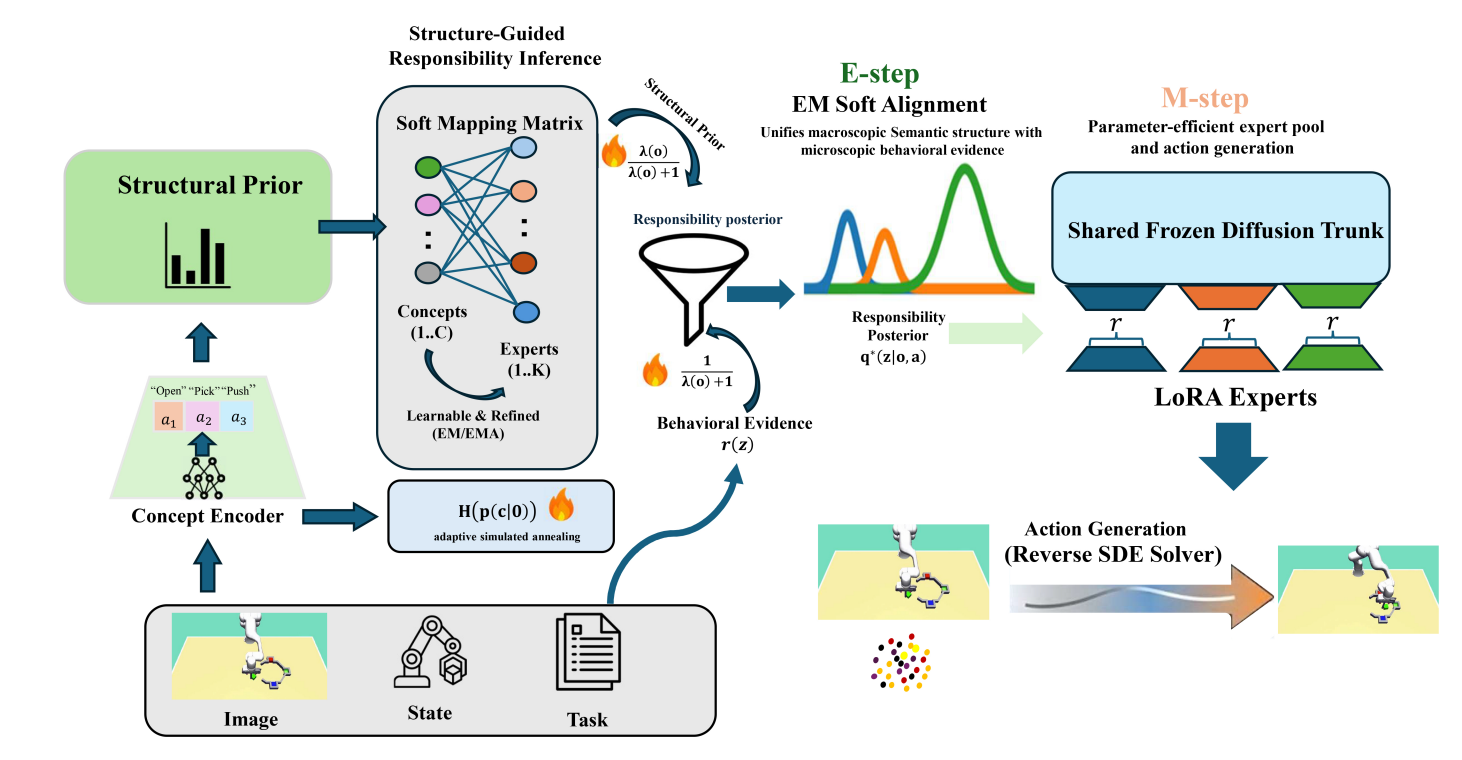
Overview figure for CoRDE: Concept-Prior Routed Diffusion Experts for Structural Generalization in Robot Manipulation

CoRDE: Concept-Prior Routed Diffusion Experts for Structural Generalization in Robot Manipulation

Haidong Huang, Xixin Zhao, Yaohua Zhou, Jiayu Song, Jiayi Zhang, Jun Ma, Haiyue Zhu, Xiaocong Li†

Accepted by IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026 Oral Presentation

Received a $1,500 travel grant from IEEE RAS.

CoRDE fuses concept priors with behavioral evidence to guide parameter-efficient LoRA diffusion experts, reducing routing collapse while preserving diverse behaviors in multi-task manipulation.
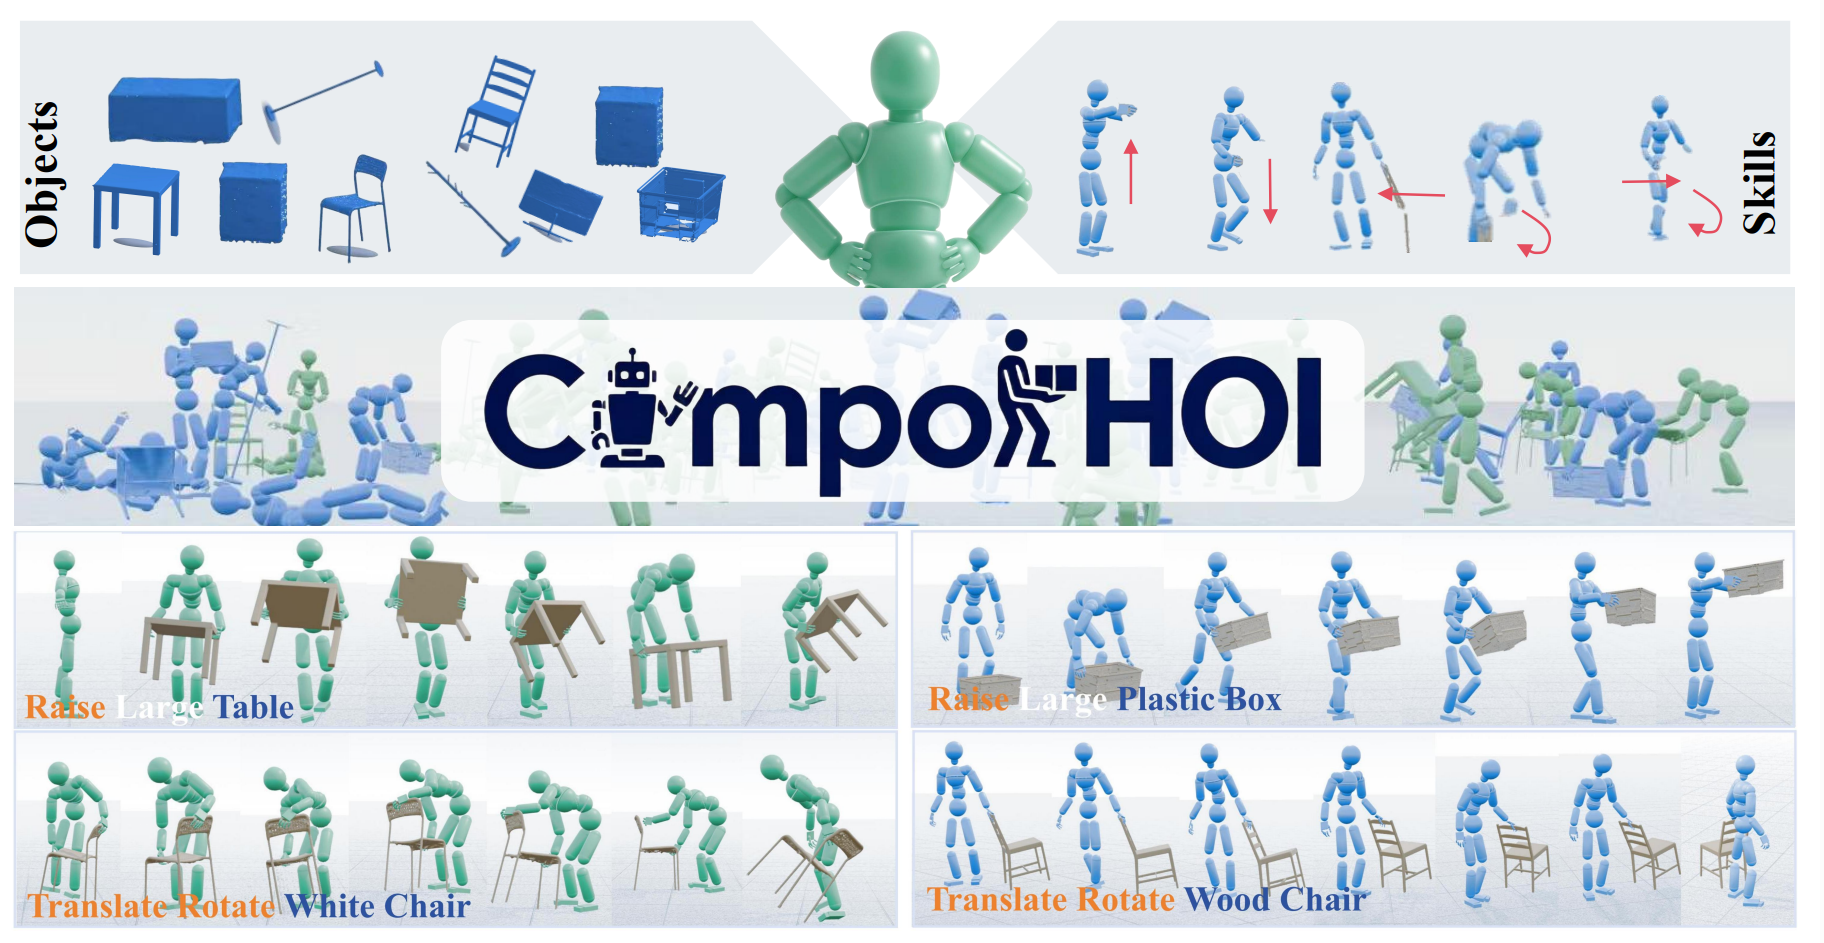
Overview figure for CompoHOI: Physics-Routed Skill–Object Recomposition for Generalizable Human–Object Interaction

CompoHOI: Physics-Routed Skill–Object Recomposition for Generalizable Human–Object Interaction

Haidong Huang, Yutong Shen, Heng Zhang, Ding Zhao

Submitted to IEEE International Conference on Computer Vision (ICCV) 2027

CompoHOI transfers learned skills to unseen skill–object combinations in physics-based human–object interaction. It separates physics-guided expert selection from motion-conditioned corrections and suppresses conflicts through directional consensus. Simulations show improved motion tracking, survival, and mean task success on combinations excluded from training.

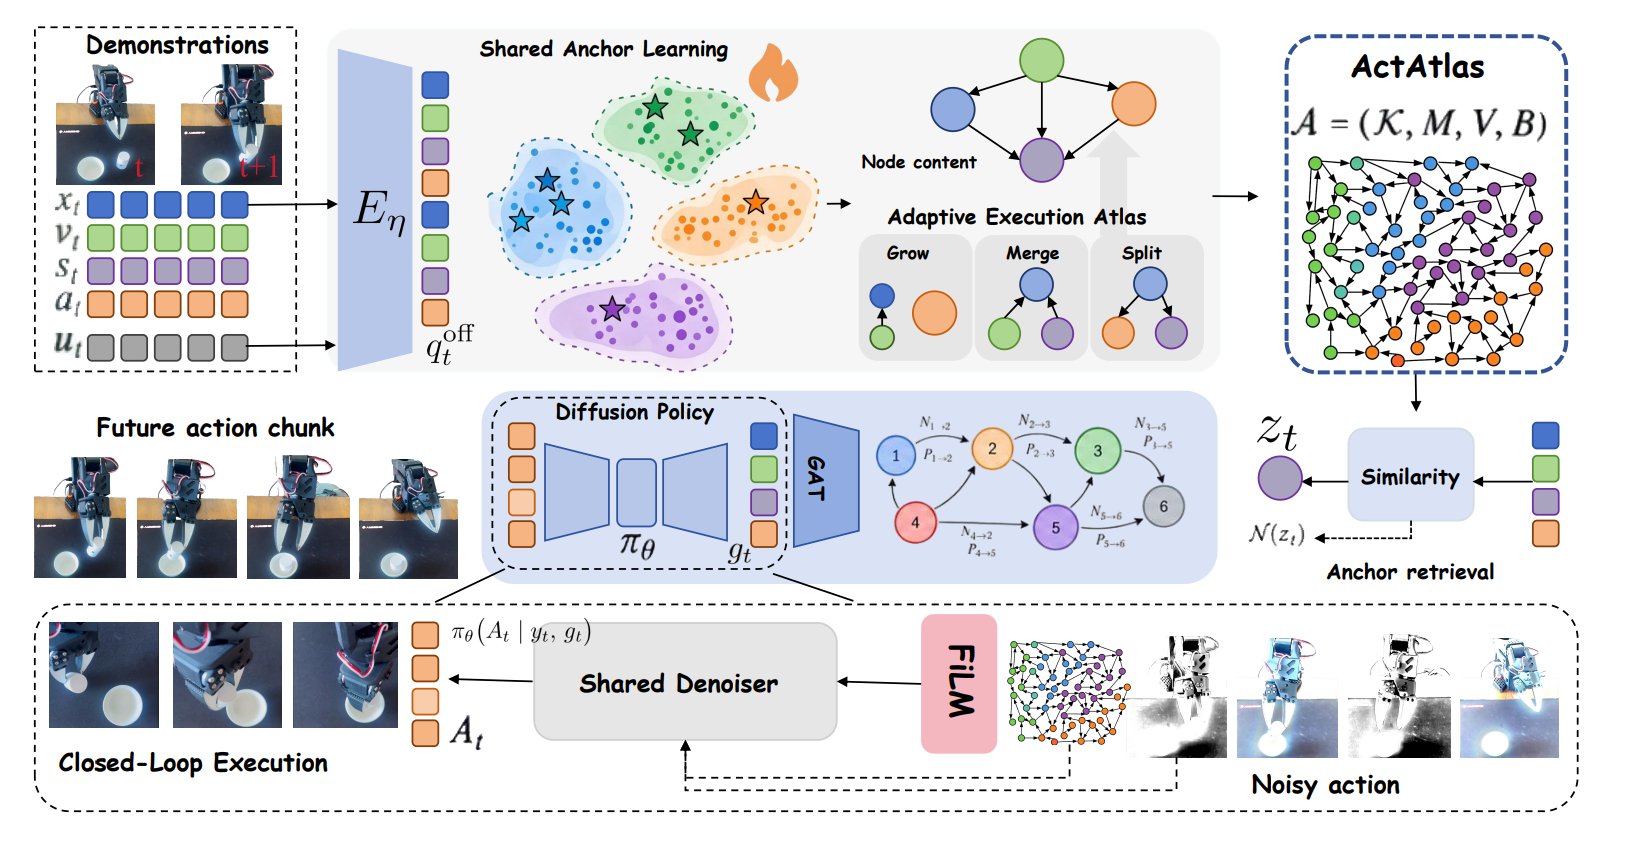
Overview figure for ActAtlas: Learning Adaptive Execution Atlases for Long-Horizon Robotic Manipulation

ActAtlas: Learning Adaptive Execution Atlases for Long-Horizon Robotic Manipulation

Haidong Huang, Yutong Shen, Heng Zhang, Xingwei Chen, Haiyue Zhu, Jun Ma, Ding Zhao†, Xiaocong Li†

Submitted to The Fifteenth International Conference on Learning Representations (ICLR) 2027

ActAtlas learns adaptive execution anchors and their directed transitions from demonstrations to condition a shared diffusion policy, distinguishing similar-looking states at different task stages and improving long-horizon manipulation.

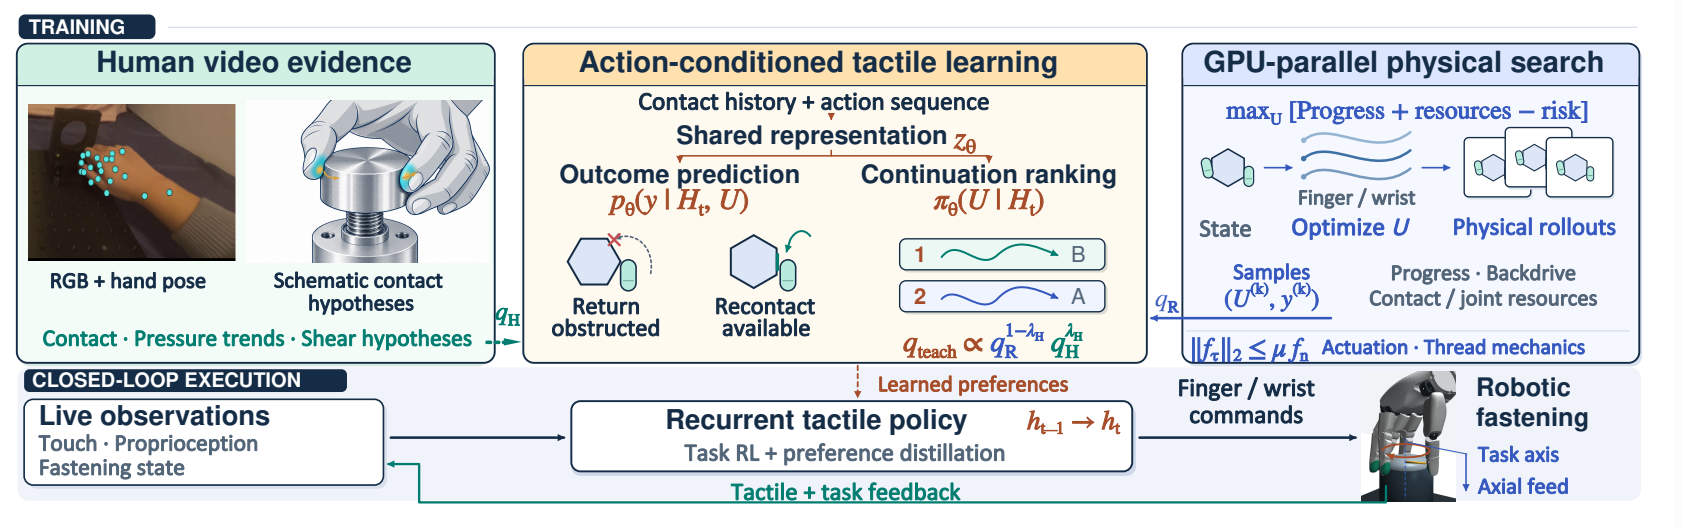
Overview figure for T-FRAME: Tactile Force-aware Representation for Action-conditioned Manipulability Evolution

T-FRAME: Tactile Force-aware Representation for Action-conditioned Manipulability Evolution

Xingwei Chen*, Haidong Huang*, Xiyuan Li, Xuqi Su, Shengjie Qiu, Tang Chong, Xiaocong Li†

Submitted to The Fifteenth International Conference on Learning Representations (ICLR) 2027

T-FRAME combines physics-supervised prediction of action-conditioned contact consequences with uncertainty-aware, video-guided preference learning to train a recurrent tactile policy for reliable, efficient dexterous fastening through repeated contact renewal without online search.

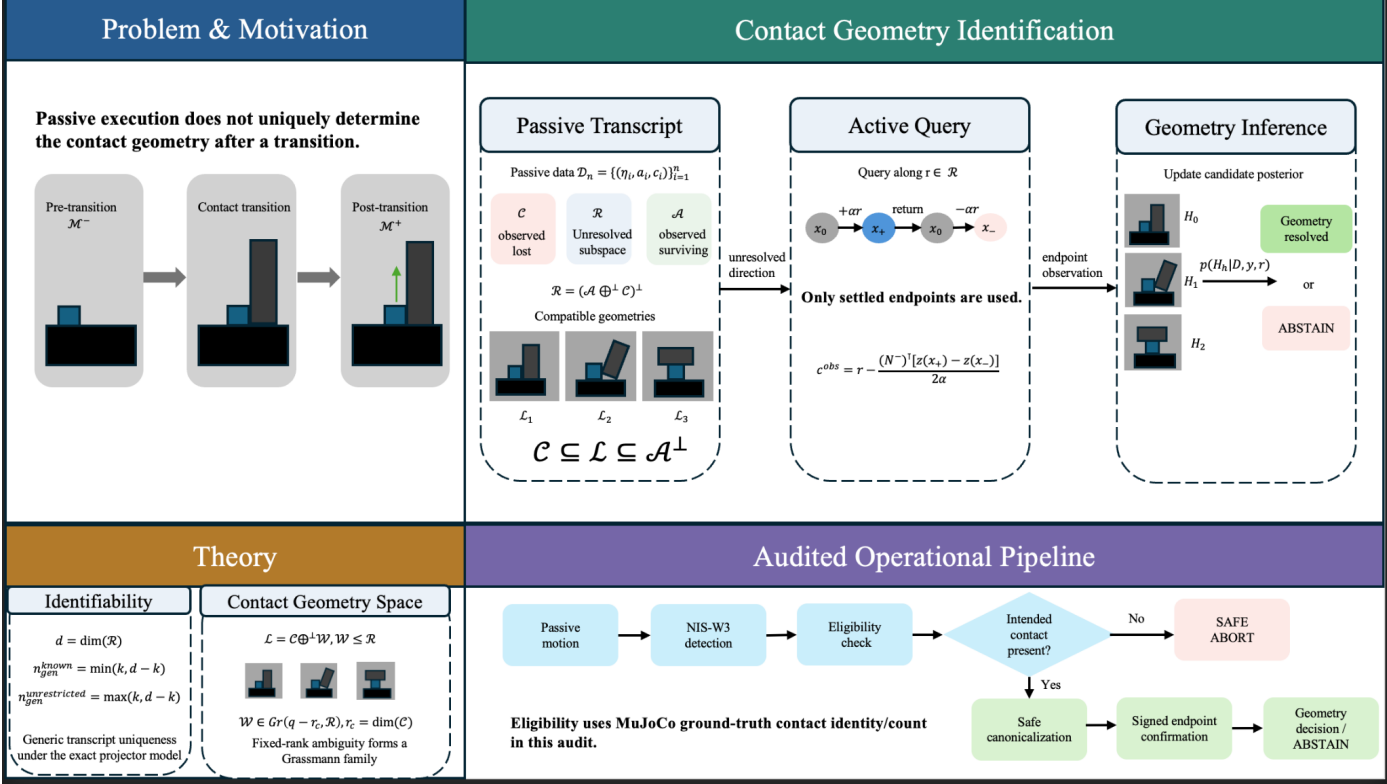
Overview figure for Identifiability and Active Confirmation of Contact Mobility Transitions

Identifiability and Active Confirmation of Contact Mobility Transitions

Xixin Zhao, Haidong Huang, Yaohua Zhou, Jiayu Song, Yuji Yamakawa†

Submitted to IEEE International Conference on Robotics and Automation (ICRA) 2027

RSS 2026 Workshop on The Geometry of Motion: Physics-Informed Structures for Learning and Control Oral Presentation

We characterize why passive execution cannot always identify contact-induced mobility loss and derive active-query requirements under an ideal projector model to guide targeted confirmation of newly constrained motions.

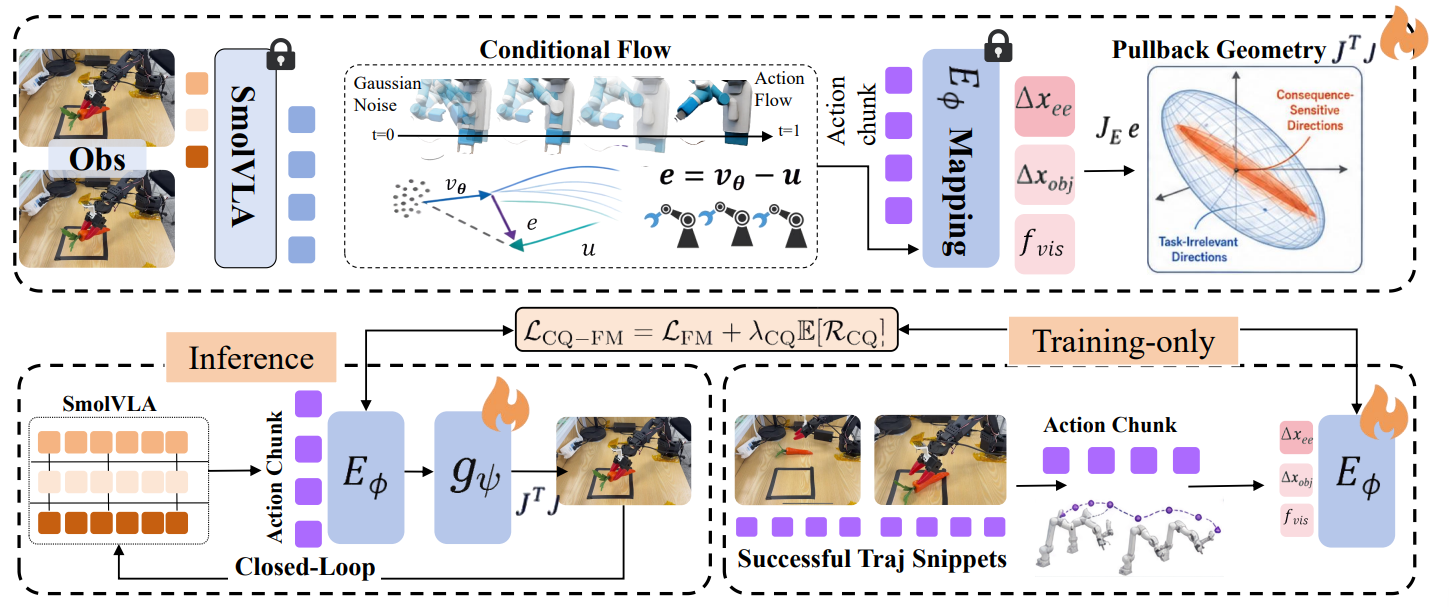
Overview figure for Consequence-Quotient Flow Matching for Robot Manipulation

Consequence-Quotient Flow Matching for Robot Manipulation

Yutong Shen*, Haidong Huang*, Heng Zhang, Haoxuan Xu, Yiqing Yin, Xuanhao Zheng, Xuhan Miao, Arash Ajoudani, Lei Zhang, Xiaocong Li†

Submitted to IEEE International Conference on Robotics and Automation (ICRA) 2027

CQ-FM uses learned action-consequence geometry to guide both flow-matching training and safeguarded closed-loop correction, improving task completion without enlarging the vision–language–action backbone.

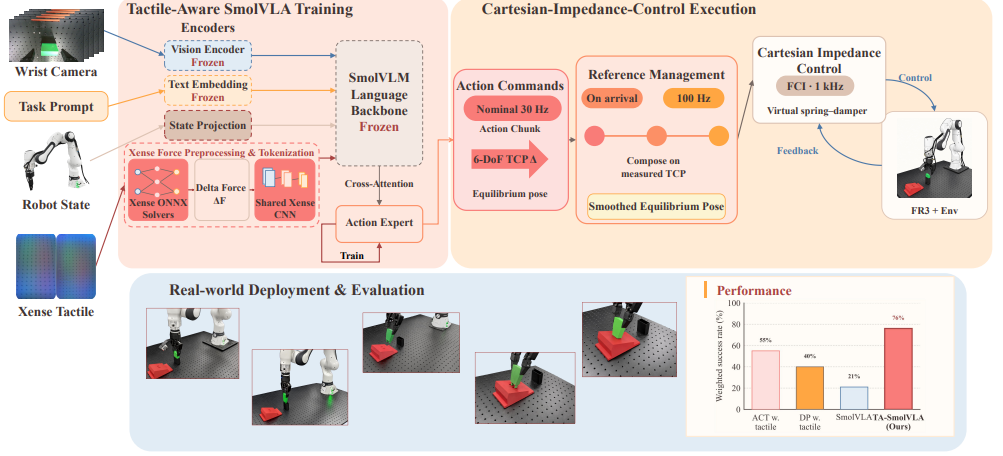
Overview figure for TA-SmolVLA: Tactile Tokens from Dense Force Fields for Contact-Rich Insertion

TA-SmolVLA: Tactile Tokens from Dense Force Fields for Contact-Rich Insertion

Xuqi Su, Yichen Wang, Mihael Simonic, Zhenxin Yu, Chan Zhang, Xingwei Chen, Haidong Huang, Yaohua Zhou, Xiaocong Li†

Submitted to IEEE International Conference on Robotics and Automation (ICRA) 2027

TA-SmolVLA integrates bilateral dense force-field tactile tokens into vision–language–action learning and connects generated actions to impedance control for more reliable, compliant plug insertion under wrist-camera occlusion.

Overview figure for A Ranking-Based Performance Normalization Method for Multi-Objective Robot Trajectory Optimization

A Ranking-Based Performance Normalization Method for Multi-Objective Robot Trajectory Optimization

Yaohua Zhou, Haidong Huang, Xixin Zhao, Gang Xu, Xiaocong Li†

Submitted to IEEE International Conference on Robotics and Automation (ICRA) 2027

NRBPEM combines rank-based normalization with sequential weighted-sum optimization to reduce sensitivity to extreme values and objective dominance, achieving faster convergence while maintaining comparable performance in multi-objective robot trajectory optimization.

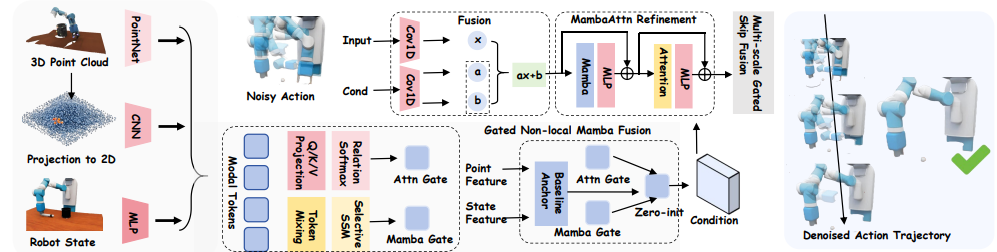
Overview figure for GeoPreserve: Preserving Action-Relevant Geometry in 3D Diffusion Policies for Long-Horizon Manipulation

GeoPreserve: Preserving Action-Relevant Geometry in 3D Diffusion Policies for Long-Horizon Manipulation

Haidong Huang*, Yutong Shen*, Xingwei Chen, Heng Zhang, Chenguang Yang, Haiyue Zhu, Jun Ma†, Xiaocong Li†

Submitted to AAAI Conference on Artificial Intelligence (AAAI) 2027

GeoPreserve uses Rewriting–Routing–Recovery to keep action-relevant 3D geometry available from observation encoding through denoising, improving long-horizon manipulation and behavioral diversity while retaining a lightweight diffusion policy.

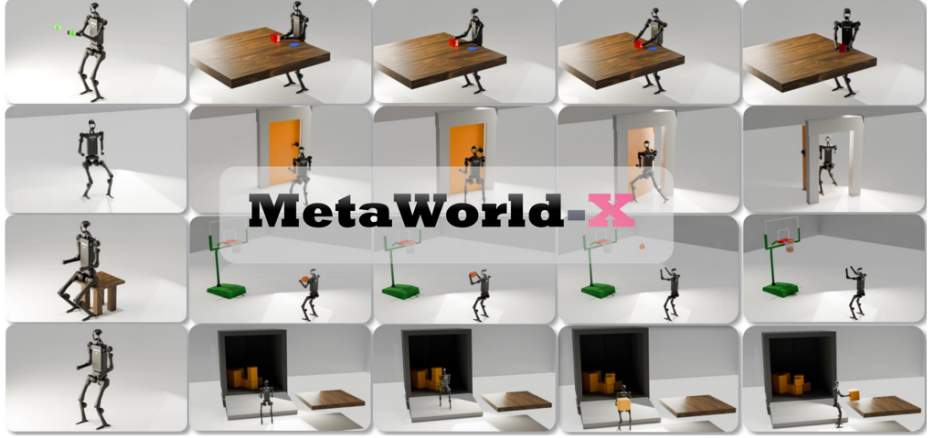
Overview figure for MetaWorld-X: Semantic-Prior Expert Orchestration with Training-Time Latent Model-Based Improvement

MetaWorld-X: Semantic-Prior Expert Orchestration with Training-Time Latent Model-Based Improvement

Yutong Shen*, Haidong Huang*, Heng Zhang, Penghui Liu, Jiashuo Luo, Zhang Shunqi, Chen Jiang, Chenguang Yang†, Arash Ajoudani, Jianwei Zhang, Lei Zhang

Submitted to IEEE International Conference on Robotics and Automation (ICRA) 2027

MetaWorld-X combines a shared latent world model, human-motion-informed experts, and VLM-guided semantic composition to reduce skill interference and support coordinated multi-stage humanoid loco-manipulation.

Overview figure for Preserving Operator Intent Under Actuation Constraints: Teleoperation of Manipulators with Coupled Transmissions

Preserving Operator Intent Under Actuation Constraints: Teleoperation of Manipulators with Coupled Transmissions (Project Leader)

Xuhan Miao, Zijin Han, Yutong Shen, Haidong Huang‡, Shanliushui Gao, Lei Zhang, Xiaocong Li, Chenguang Yang†

Accepted by 5th Sensorimotor-Augmented Teleoperation Workshop @ IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026 Oral Presentation

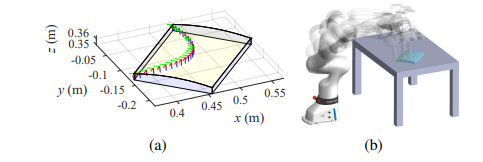
Our teleoperation framework combines gravity-aware actuator-space projection with continuous feasible-reference updates to preserve operator intent and reduce coordination distortion and recovery transients in manipulators with coupled transmissions.

Overview figure for Joint-Angle Invariance of Jacobian-Based Performance Indices for Serial Robotic Manipulators

Joint-Angle Invariance of Jacobian-Based Performance Indices for Serial Robotic Manipulators

Yaohua Zhou, Mingdao Lin, Jiayu Song, Xixin Zhao, Haidong Huang, Jiahu Qin, Xiaocong Li†

Accepted by IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026 Oral Presentation

We identify when Jacobian-based performance indices are invariant to the first and last joint angles, enabling lower-dimensional performance mapping and task-layout optimization with reduced computational and storage costs.

Overview figure for Opinion: Towards Unified Expressive Policy Optimization for Robust Robot Learning

Opinion: Towards Unified Expressive Policy Optimization for Robust Robot Learning

Haidong Huang, Haiyue Zhu, Jiayu Song, Xixin Zhao, Yaohua Zhou, Jiayi Zhang, Yuze Zhai, Xiaocong Li†

Accepted by EWM Workshop @ Conference on Neural Information Processing Systems (NeurIPS) 2025 Spotlight

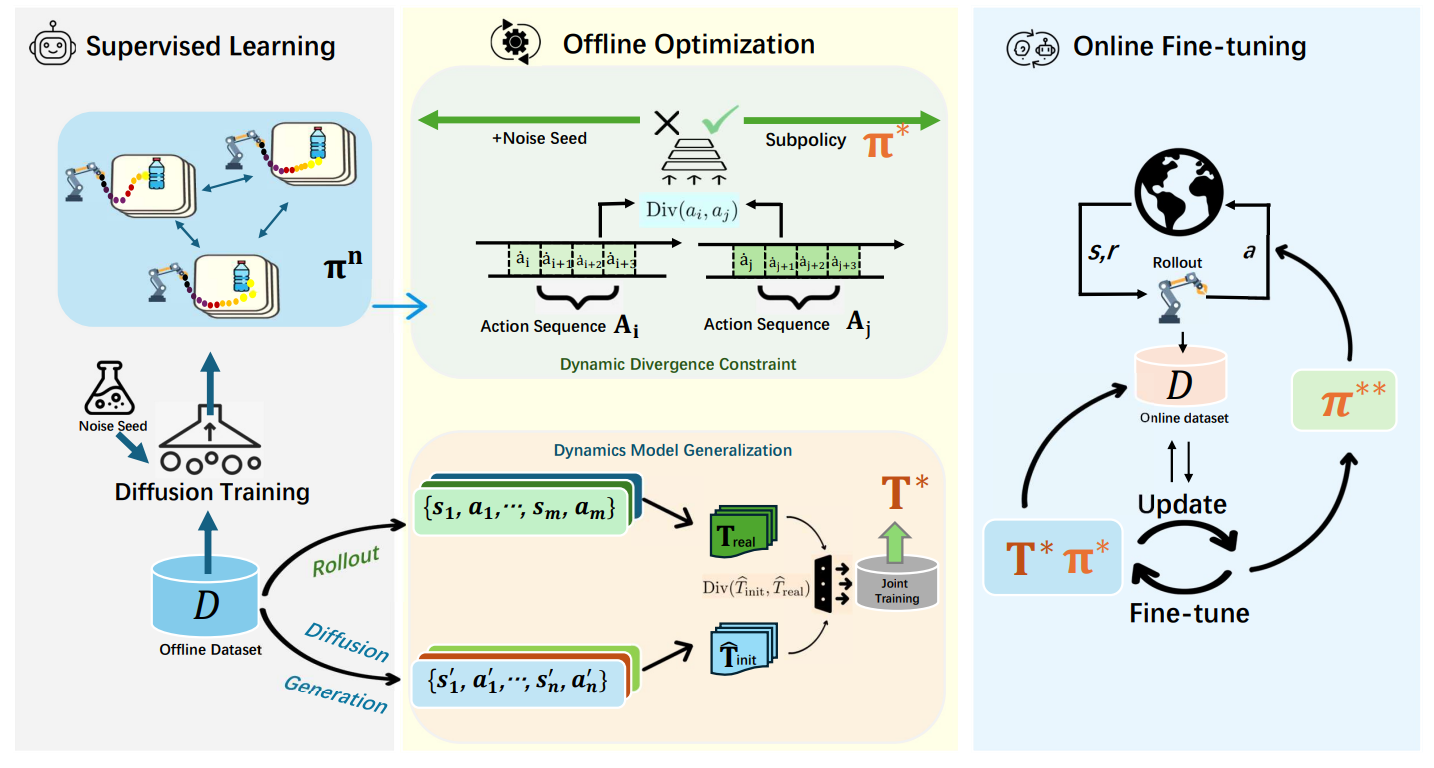
UEPO combines multi-seed diffusion sampling, dynamic divergence regularization, and trajectory augmentation to broaden behavioral coverage and improve dynamics-model generalization for offline-to-online robot learning using a single generative policy.

View complete publication list →

Honors & Awards

Education

  1. Bachelor of Engineering (Hons)

    University of Nottingham (China Campus)

    Sep. 2024 - Jun. 2028 (Expected)

Research Experience

  1. Research Intern

    Carnegie Mellon University (CMU)

    Robotics Institute

    SafeAI Lab

    Advised by Prof. Ding Zhao

    Research: Dexterous manipulation; generative control policy

    Sep. 2026 - Dec. 2026

  2. Visiting Student

    The Hong Kong Polytechnic University (PolyU)

    Faculty of Computer and Mathematical Sciences

    Advised by Prof. Chenguang (Charlie) Yang

    Research: Robot manipulation; learning from demonstrations

    May 2026 - Sep. 2026

  3. Visiting Student

    The Hong Kong University of Science and Technology (HKUST)

    Robot Motion Planning and Control Lab

    Advised by Prof. Jun Ma

    Research: Dexterous manipulation; robot manipulation

    Jun. 2026 - Oct. 2026

  4. Undergraduate Researcher

    Eastern Institute of Technology, Ningbo (EIT)

    Robot Learning and Control Lab

    Advised by Prof. Xiaocong Li

    Research: Robot manipulation; embodied AI; control

    Apr. 2025 - Present

Academic Services

Miscellaneous

I have a passion for robots; the first movie I ever watched was Real Steel, and my all-time favorite is Big Hero 6. I have loved robots since I was young and dreamed of building one of my own—a dream that is now gradually becoming a reality. ☀️

During high school, I was deeply immersed in Physics and Chemistry Olympiad competitions, with a particular passion for mechanics. These experiences ignited my enthusiasm for research into enabling robots to engage in contact-rich interactions with the world around them. I love physics; it allows us to gain a profound, fundamental understanding of the world while simultaneously helping us better understand ourselves.

Beyond my research, I enjoy playing basketball, soccer, and table tennis. I am an NBA fan, and my favorite basketball players are Kyrie Irving and Kevin Durant 🏀. I am also a huge fan of Lionel Messi ⚽ and Fan Zhendong 🏓.

I love rap music and have a particular fondness for gospel music. My favorite artists are Kanye West and ASEN. Music has extraordinary power.

“What I cannot create, I do not understand.”

— Richard P. Feynman